Graduate Teaching Assistant
Penn State University
Aug 2026 – Present
Teaching assistant for CMPEN 270: Digital Design, Theory and Practice, alongside doctoral research in cyber-physical systems security.
Autonomous & Embedded Systems Engineer
PhD Student, Computer Science and Engineering
Penn State University · State College, Pennsylvania
I build and evaluate autonomous systems, from UAV autopilots and avionics to production C++ software for automotive ADAS. My experience spans control systems, embedded software, system integration, and engineering validation.
At Penn State, I am extending that work into cyber-physical systems security through sensor emulation and firmware evaluation.
Penn State University
Aug 2026 – Present
Teaching assistant for CMPEN 270: Digital Design, Theory and Practice, alongside doctoral research in cyber-physical systems security.
SoftwareMotion Co., Ltd.
Dec 2024 – Aug 2026
Developed production C++ ADAS control software, with software-in-the-loop testing, fleet-data analysis, and test automation. Led and mentored a team of five engineers.
National Centre for Unmanned Aerial Systems
Dec 2021 – Apr 2026
Led UAV control and navigation development, autopilot and avionics integration, and verification and validation across six platforms, including bench, HIL, and flight testing.
Concurrent with SoftwareMotion, Dec 2024 – Apr 2026.
National Centre for Unmanned Aerial Systems
Nov 2019 – Dec 2021
Developed embedded control and communication software; integrated sensors, avionics, and onboard computing through calibration and bench testing.
In development
Current research · Flight control software validation
Developing high-fidelity sensor peripheral models in OpenModelica to emulate real sensor behavior and communication protocols. The models are intended to work with rehosted flight control firmware, such as ArduPilot or PX4, for pseudo hardware-in-the-loop (HITL) testing and validation of flight control software.
Technical focus OpenModelica · ArduPilot / PX4 · Sensor emulation
Academic systems project
An operating systems project exploring POSIX threads, ucontext-based context creation and switching, and cross-machine communication and synchronization concepts.
Technical focus POSIX threads · ucontext · Context switching
Master’s thesis · Published at IFAC World Congress 2020
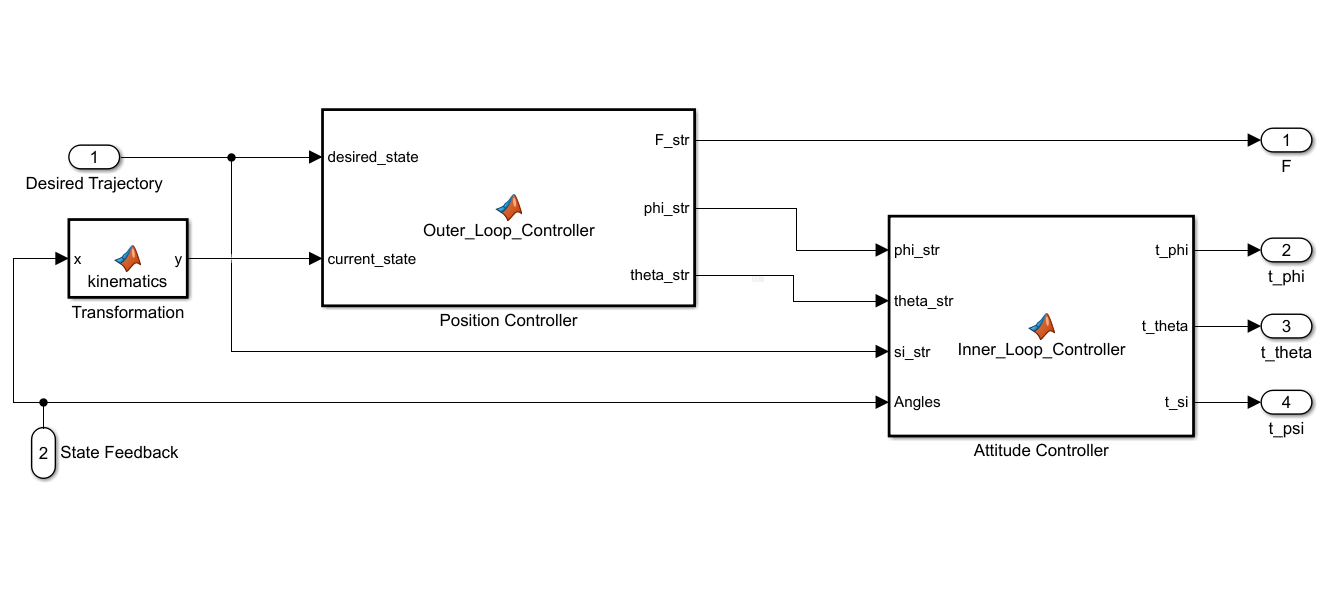
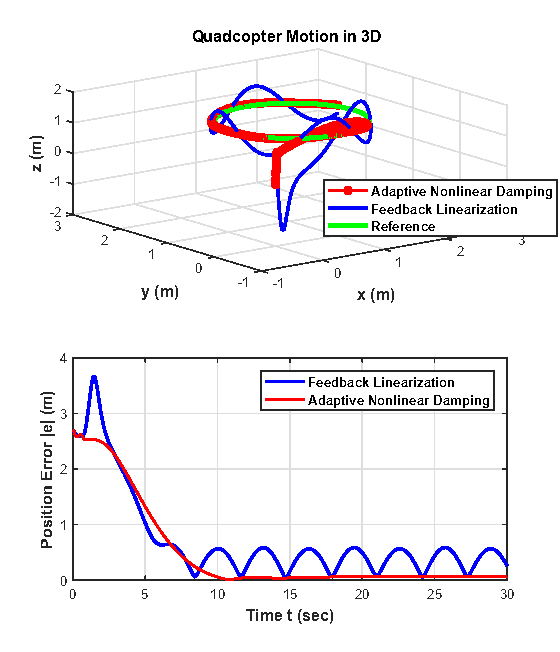
Modeled nonlinear quadcopter dynamics and designed feedback linearization, sliding mode, and backstepping control for trajectory tracking under disturbances and uncertainty. This simulation study led to the IFAC World Congress 2020 publication.
Technical focus MATLAB / Simulink · Nonlinear dynamics · Robust control
Interactions between physical sensors, communication interfaces, and embedded device drivers.
Behavioral sensor models and simulation-based methods for testing embedded firmware.
Control, navigation, and estimation under abnormal sensor inputs, faults, and adversarial conditions.
M. Z. Ali, A. Ahmed, and H. K. Afridi
IFAC World Congress 2020 · IFAC-PapersOnLine, 53(2), 8840–8846.
Penn State University
2026–2031 (expected)
Pakistan Institute of Engineering & Applied Sciences (PIEAS)
2017–2019
Second Best Thesis Award
National University of Sciences and Technology (NUST)
2013–2017
Silver Medal · Merit scholarship